
ENGINEERING NOTES / CABLE DISPLACEMENT
Draw-wire sensor accuracy, linearity & working principle.
A spring-return cable turns a drum. A potentiometer or encoder converts drum rotation into a position signal.
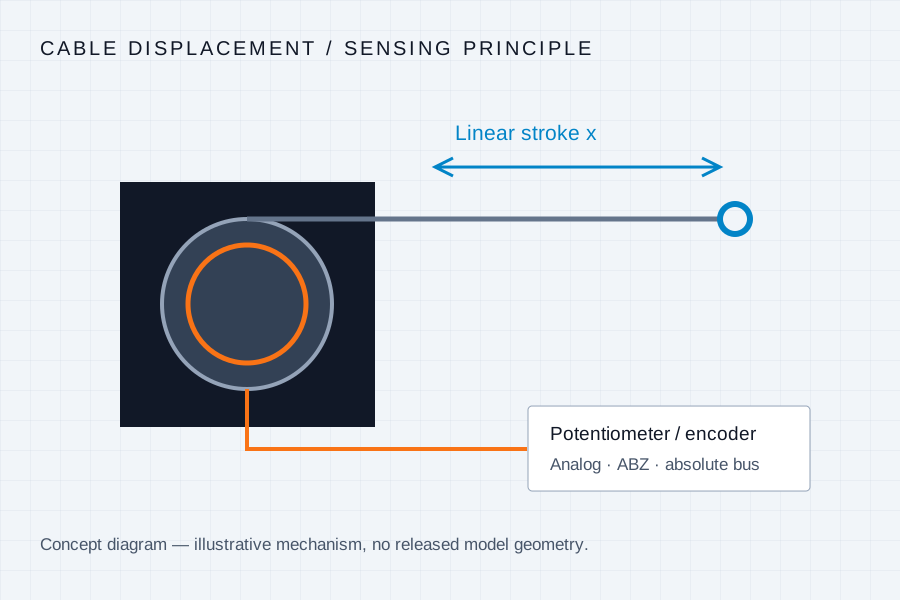
From drum rotation to linear displacement
For a constant effective drum circumference C, travel x = C × revolutions. An encoder produces a pulse count or an absolute angular value; a string potentiometer produces a voltage ratio that is conditioned or measured by a suitable input.
Resolution, linearity and repeatability answer different questions.
| Quantity | Meaning | Practical check |
|---|---|---|
| Resolution | Smallest indicated or encoded increment | Drum circumference / effective decoded counts per revolution |
| Linearity | Deviation from a defined straight-line reference | Specify reference method and %FS, then convert to mm |
| Repeatability | Spread of repeated measurements at the same position | Check direction, temperature, tension and test conditions |
| System accuracy | Combined measurement error under stated conditions | Include sensor, readout, DAQ, temperature and mounting effects |
Example: ±0.05% FS over 1,000 mm corresponds to ±0.5 mm linearity. A 0.01 mm count size would not establish ±0.01 mm system accuracy. For a 200 mm drum circumference and 20,000 effective counts per revolution, resolution is 0.01 mm/count. Define whether ABZ counts are decoded at ×1, ×2 or ×4.
Make the analog channel match the controller.
A voltage divider needs a stable excitation and sufficiently high input impedance. A 4–20 mA transmitter needs the correct two-wire or three-wire circuit, supply compliance and loop burden. Confirm zero / span mapping and the receiving device’s input specification.
At 100 m, the installation is part of the measurement.
Long free cable spans introduce sag, thermal expansion and wind effects. Define cable tension, support, routing and drum wrap geometry. A guide pulley changes routing; an extension cable offsets the anchor and does not increase the sensor’s calibrated stroke.
Which documents should accompany a quotation?
Ask for the configuration-specific stroke, line speed and acceleration limits, retract force, output wiring, dimensional drawing and calibration scope. For a bus encoder, include its device description and position recovery behavior. IP ratings require stated test conditions for the complete assembly.
Further reading: SICK wire-draw position scaling · Micro-Epsilon installation manual directory.
Specify your stroke & signal